Algorithms
-

HAPPY.PLACE
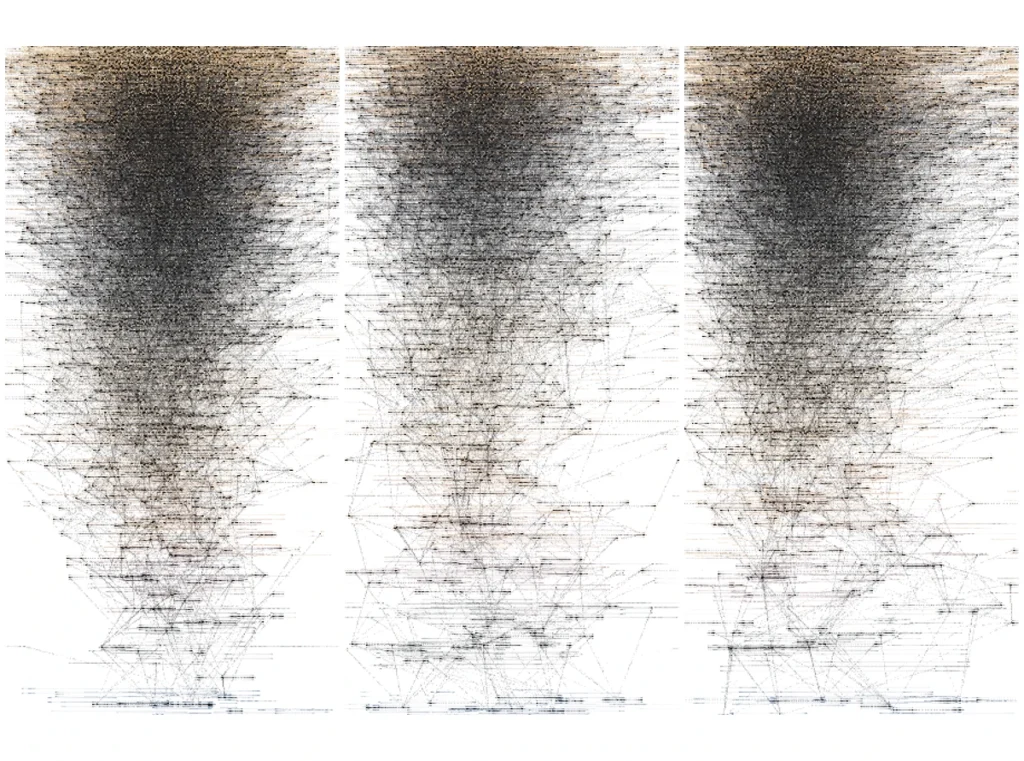
Happy Place renders the resulting configuration of a system of friendly nodes. They are connected at random with preferences to nodes closer.
-
OFFSPRING
Offspring is a visualization of the pair bonding process of a theoretical robot colony. Each robot is assembled, ages through youth, comes into a reproductive stage, and eventually dies of fatigue.
-

BIT.10001
Exposing the paths of particles as they accelerate around an infinite numerical attractor, we see a process of flow ranging from gentle to chaotic. It is an amazing thing to render 10,001 particles, in three dimensions, in real time.
-

CUBIC.ATTRACTOR
A minimalist modification of the City Traveler system. Cities are initiated in grid locations.
-
BUDDHA.BROT
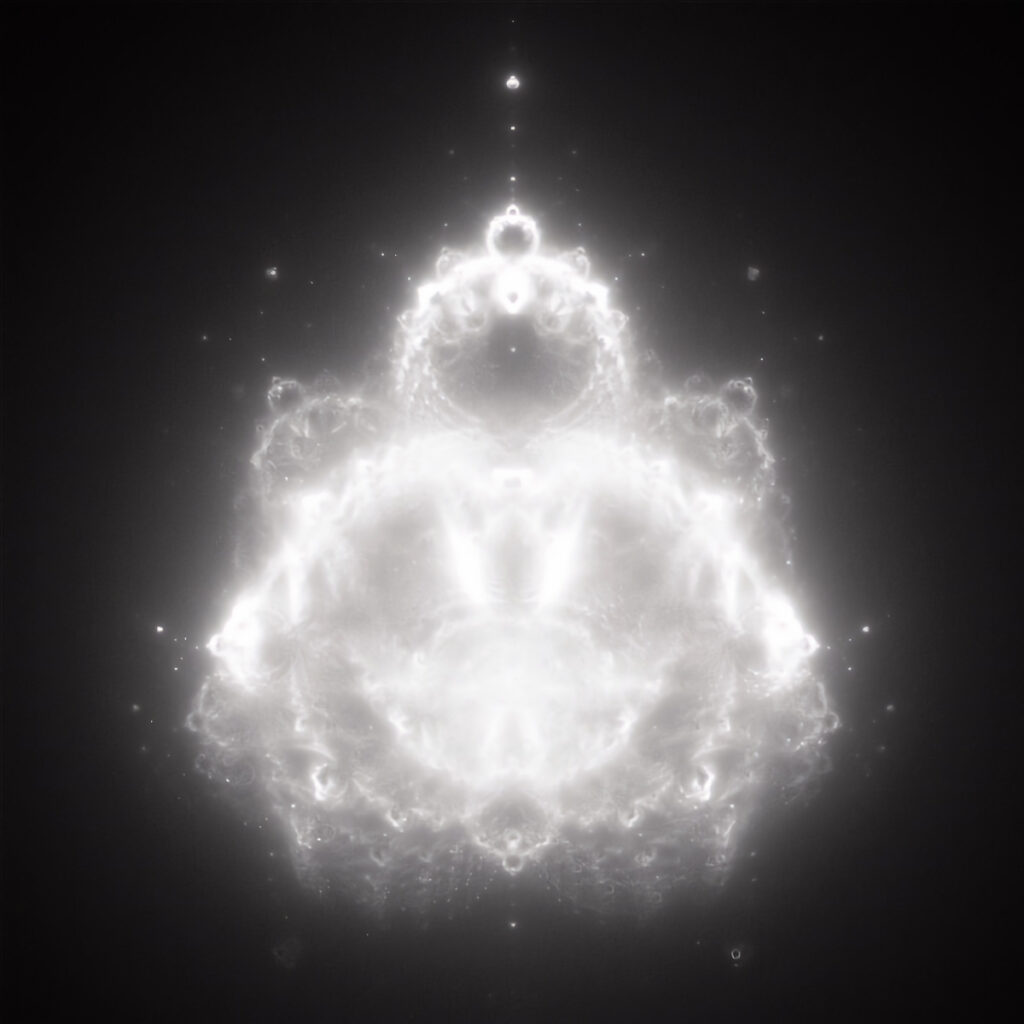
The Buddhabrot Set is a re-visualization of the familiar Mandelbrot Set using a technique invented by Melinda Green. Instead of selecting points on the real-complex plane, initial points are selected at random from the image region.
-

LIMB.STROKE.VARIATION.E
Slight changes in the attributes of the limb structure produce unique species grouped structures. Fundamentally similar, yet aesthetically different, huge populations of these computational artifacts can be rendered with a single identical exposure.
-

LIMB.STROKE.VARIATION.D
Variation D explores momentary exposures and a more detailed stroke across each limb. 0000 Short exposure, reduced 50% and cropped 0001 Shorter exposure, reduced 50% and cropped
-

LIMB.STROKE.VARIATION.C
Further refinement 0005 0002
-

LIMB.STROKE.VARIATION.B
A nice set of value ranges was discovered in variation A and examined in more detail here. Instead of rendering an entire field of limb structures, we render only one.
-

LIMB.STROKE.VARIATION.A
The Limb Stroke is an interesting generative painting system based on the radial motions of recursive limb structures. 1001 1000
-

LIMB.STRAT
The limb structure calls itself to render. Strokes are taken perpendicular to the limb's direction of growth.
-

BOX.FITTING
A region of space is filled through exhaustive placement of slowly expanding boxes. Each box begins very small (2 x 2 pixels) and increases in size until an obstacle (surface border or other box) is encountered.